Overall detection
1.Introduction
MediaPipe is an open-source data stream processing machine learning application development framework developed by Google. It is a graph-based data processing pipeline used to build data sources in various forms, such as video, audio, sensor data, and any time series data. MediaPipe is cross-platform and can run on embedded platforms (such as Raspberry Pi), mobile devices (iOS and Android), workstations and servers, and supports mobile GPU acceleration. MediaPipe provides cross-platform, customizable ML solutions for real-time and streaming media.
The core framework of MediaPipe is implemented in C++ and provides support for languages such as Java and Objective C. The main concepts of MediaPipe include packets, streams, calculators, graphs, and subgraphs.
Features of MediaPipe:
- End-to-end acceleration: built-in fast ML inference and processing can be accelerated even on ordinary hardware.
- Build once, deploy anywhere: unified solution for Android, iOS, desktop/cloud, web, and IoT.
- Ready-to-use solution: cutting-edge ML solution that showcases the full capabilities of the framework.
- Free and open source: framework and solution under Apache 2.0, fully extensible and customizable.
2. MediaPipe Hands
Refer to the【hand detection】course.
3. MediaPipe Pose
Refer to the【Posture detection】course.
4. Overall detection
Combining the content of the previous course, this course can detect both palms and human bodies.
4.1 Start
- Input following command to start the program
roscore
rosrun jetcobot_mediapipe 03_Holistic.py
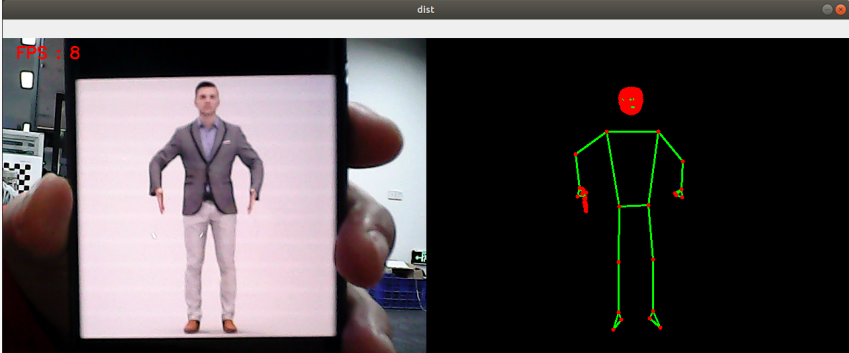
4.2 Code
Code path:~/jetcobot_ws/src/jetcobot_mediapipe/scripts/03_Holistic.py
#!/usr/bin/env python3
# encoding: utf-8
import time
import rospy
import cv2 as cv
import numpy as np
import mediapipe as mp
from geometry_msgs.msg import Point
from hemihex_msgs.msg import PointArray


class Holistic:
def __init__(self, staticMode=False, landmarks=True, detectionCon=0.5, trackingCon=0.5):
self.mpHolistic = mp.solutions.holistic
self.mpFaceMesh = mp.solutions.face_mesh
self.mpHands = mp.solutions.hands
self.mpPose = mp.solutions.pose
self.mpDraw = mp.solutions.drawing_utils
self.mpholistic = self.mpHolistic.Holistic(
static_image_mode=staticMode,
smooth_landmarks=landmarks,
min_detection_confidence=detectionCon,
min_tracking_confidence=trackingCon)
self.pub_point = rospy.Publisher('/mediapipe/points', PointArray, queue_size=1000)
self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=3)
self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=2, circle_radius=2)

def findHolistic(self, frame, draw=True):
pointArray = PointArray()
img = np.zeros(frame.shape, np.uint8)
img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB)
self.results = self.mpholistic.process(img_RGB)
if self.results.face_landmarks:
if draw: self.mpDraw.draw_landmarks(frame, self.results.face_landmarks, self.mpFaceMesh.FACEMESH_CONTOURS, self.lmDrawSpec, self.drawSpec)
self.mpDraw.draw_landmarks(img, self.results.face_landmarks, self.mpFaceMesh.FACEMESH_CONTOURS, self.lmDrawSpec, self.drawSpec)
for id, lm in enumerate(self.results.face_landmarks.landmark):
point = Point()
point.x, point.y, point.z = lm.x, lm.y, lm.z
pointArray.points.append(point)
if self.results.pose_landmarks:
if draw: self.mpDraw.draw_landmarks(frame, self.results.pose_landmarks, self.mpPose.POSE_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
self.mpDraw.draw_landmarks(img, self.results.pose_landmarks, self.mpPose.POSE_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
for id, lm in enumerate(self.results.pose_landmarks.landmark):
point = Point()
point.x, point.y, point.z = lm.x, lm.y, lm.z
pointArray.points.append(point)
if self.results.left_hand_landmarks:
if draw: self.mpDraw.draw_landmarks(frame, self.results.left_hand_landmarks, self.mpHands.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
self.mpDraw.draw_landmarks(img, self.results.left_hand_landmarks, self.mpHands.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
for id, lm in enumerate(self.results.left_hand_landmarks.landmark):
point = Point()
point.x, point.y, point.z = lm.x, lm.y, lm.z
pointArray.points.append(point)
if self.results.right_hand_landmarks:
if draw: self.mpDraw.draw_landmarks(frame, self.results.right_hand_landmarks, self.mpHands.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
self.mpDraw.draw_landmarks(img, self.results.right_hand_landmarks, self.mpHands.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec)
for id, lm in enumerate(self.results.right_hand_landmarks.landmark):
point = Point()
point.x, point.y, point.z = lm.x, lm.y, lm.z
pointArray.points.append(point)
self.pub_point.publish(pointArray)
return frame, img

def frame_combine(slef,frame, src):
if len(frame.shape) == 3:
frameH, frameW = frame.shape[:2]
srcH, srcW = src.shape[:2]
dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8)
dst[:, :frameW] = frame[:, :]
dst[:, frameW:] = src[:, :]
else:
src = cv.cvtColor(src, cv.COLOR_BGR2GRAY)
frameH, frameW = frame.shape[:2]
imgH, imgW = src.shape[:2]
dst = np.zeros((frameH, frameW + imgW), np.uint8)
dst[:, :frameW] = frame[:, :]
dst[:, frameW:] = src[:, :]
return dst


if __name__ == '__main__':
rospy.init_node('Holistic', anonymous=True)
capture = cv.VideoCapture(0)
capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G'))
capture.set(cv.CAP_PROP_FRAME_WIDTH, 640)
capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480)
print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS))
pTime = cTime = 0
holistic = Holistic()
while capture.isOpened():
ret, frame = capture.read()
# frame = cv.flip(frame, 1)
frame, img = holistic.findHolistic(frame,draw=False)
if cv.waitKey(1) & 0xFF == ord('q'): break
cTime = time.time()
fps = 1 / (cTime - pTime)
pTime = cTime
text = "FPS : " + str(int(fps))
cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.8, (0, 0, 255), 2)
dist = holistic.frame_combine(frame, img)
cv.imshow('dist', dist)
# cv.imshow('frame', frame)
# cv.imshow('img', img)
capture.release()
cv.destroyAllWindows()